Teleoperation Data Collection: How to store and capture teleop data
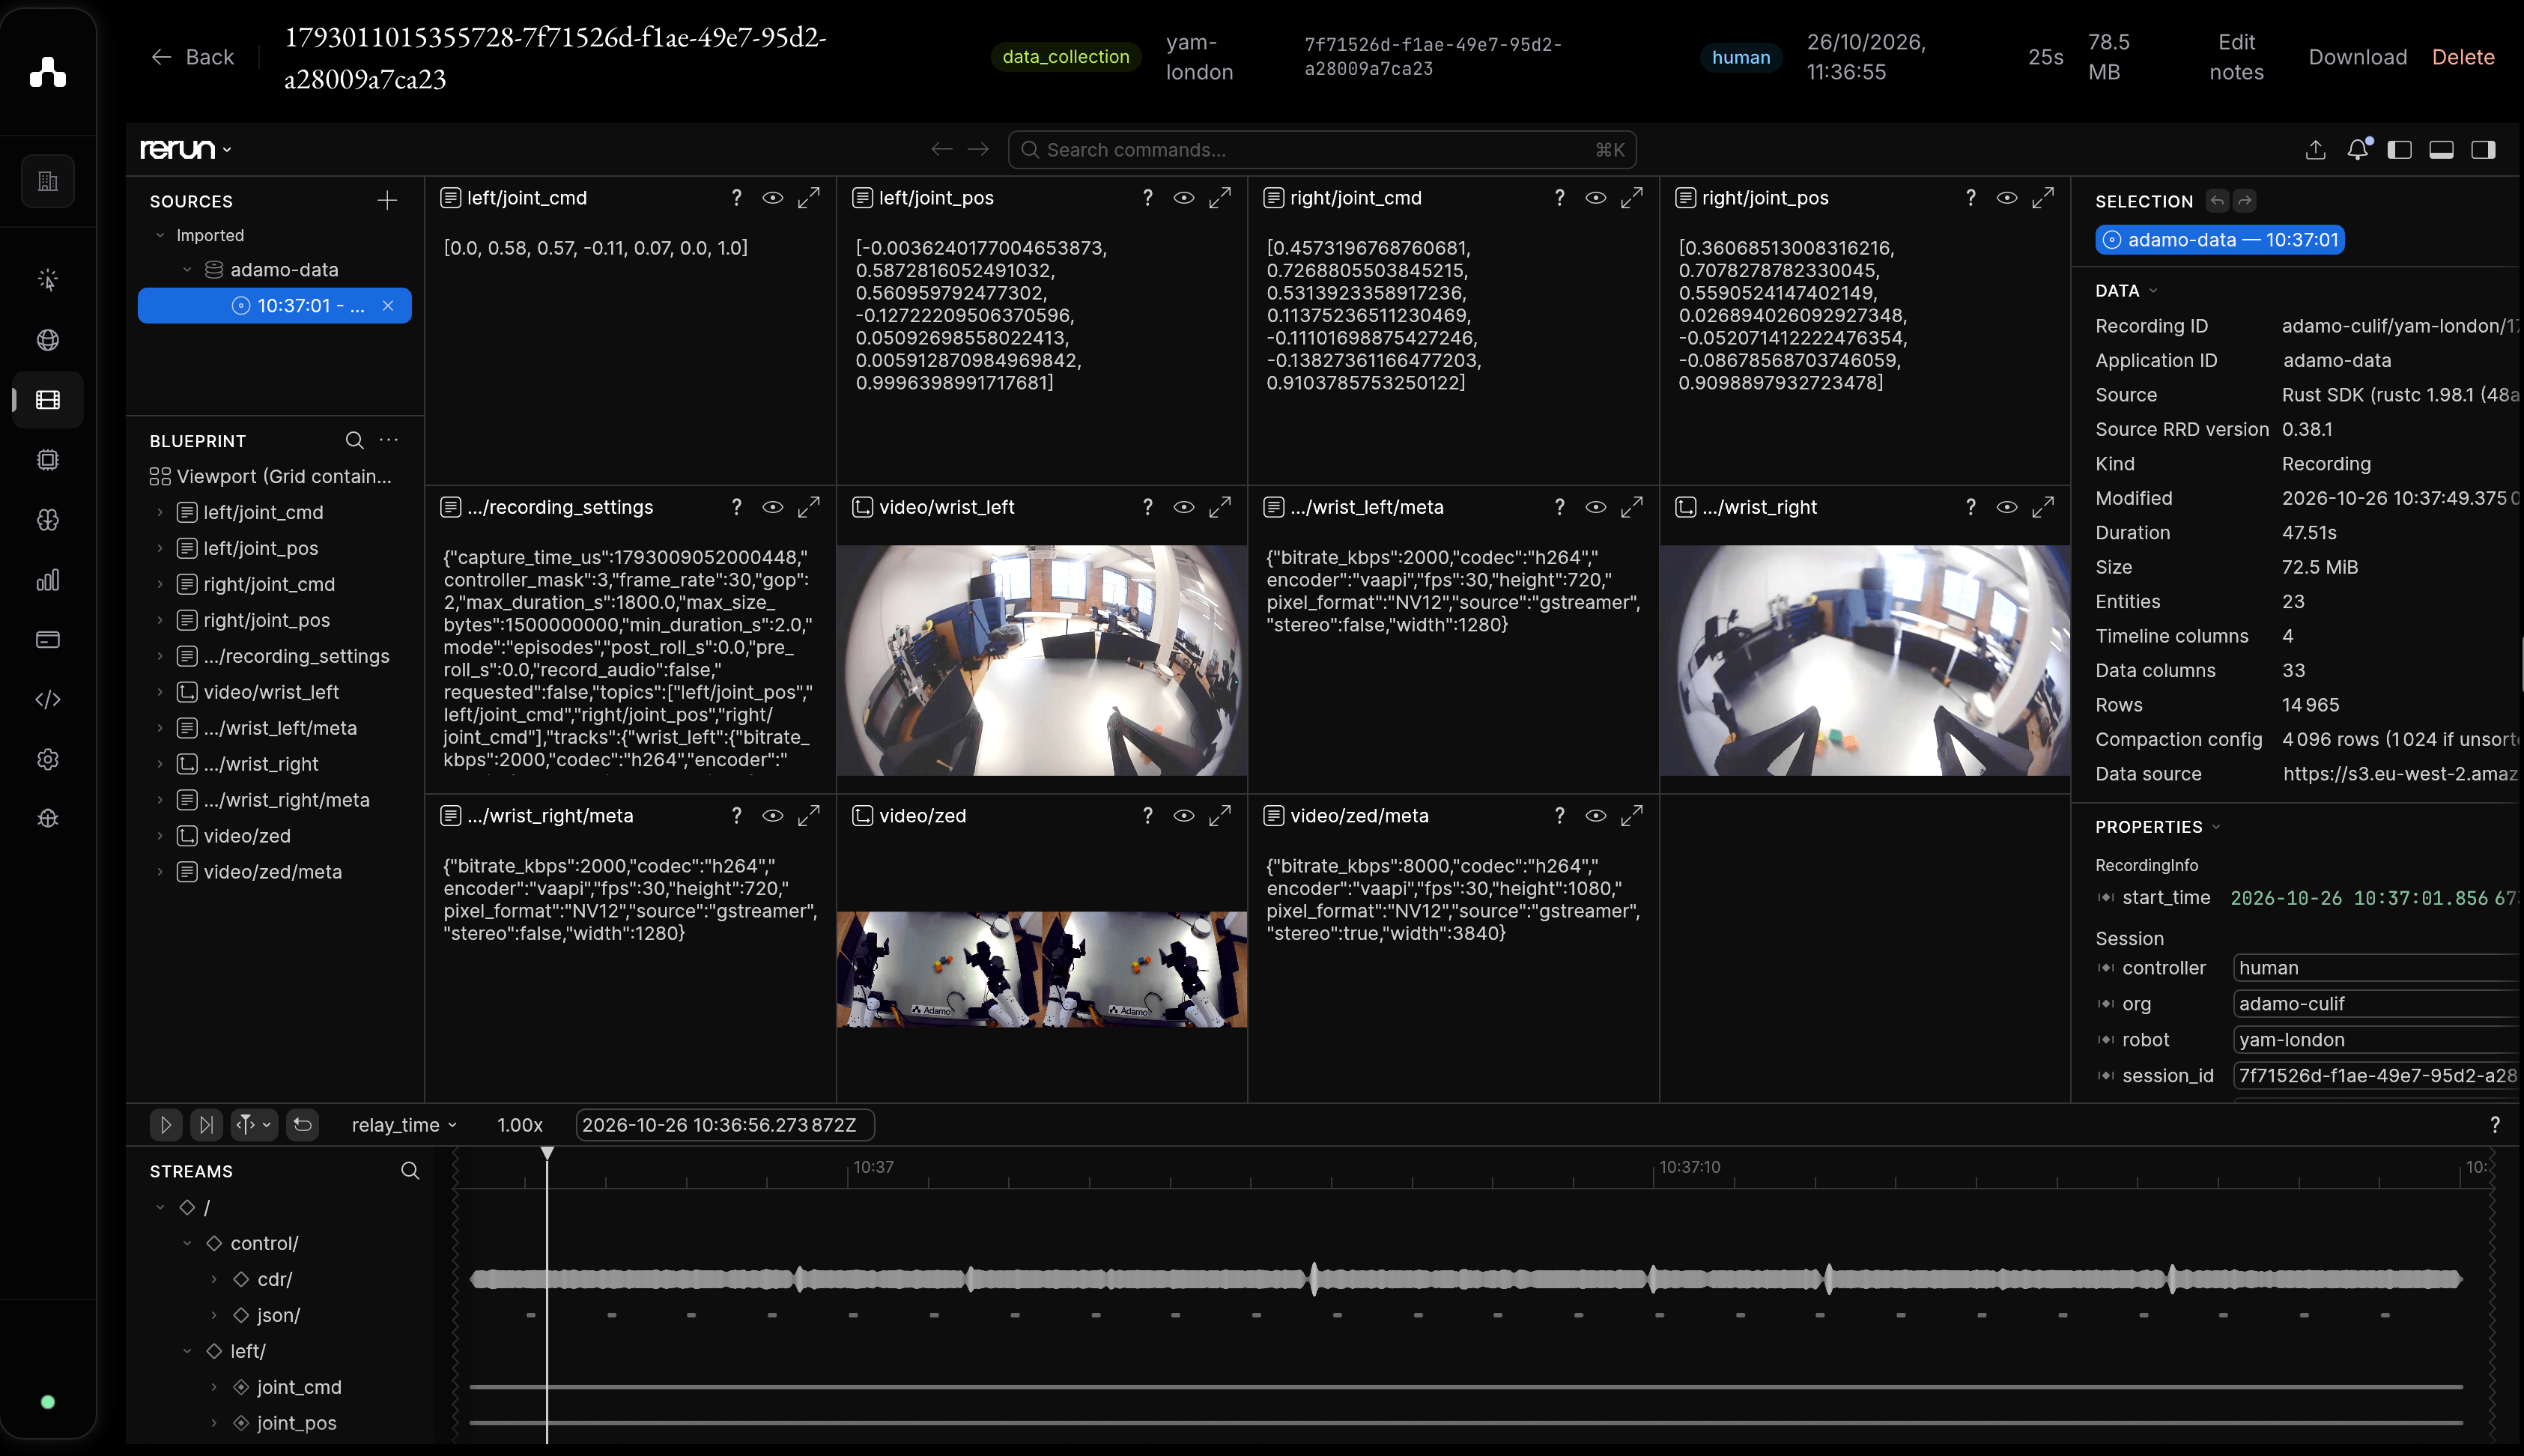
The interventions your operators handle today are the training data your autonomy stack needs tomorrow. Most teams throw that data away without realizing... more »
Best Teleoperation Software for Humanoid Robots (2026)
TLDR: Humanoid teleoperation software splits into two jobs. One is capturing demonstrations in the lab, with an operator in a headset on the same network... more »
The Best Teleoperation Platform for Humanoid Robots
Humanoids are the hardest thing you can put on the other end of a remote connection. Here is what separates a teleoperation platform that survives that from... more »
Robot Teleoperation vs Autonomy: Why Human in the Loop Still Matters
Full autonomy is the goal every robotics roadmap points at, but the machines shipping today still hand the hard moments to a person. Here is why that... more »
Adamo Pub/Sub: A Better Teleoperation Developer Experience
Every teleoperation vendor promises low latency. Far fewer can answer the question that actually predicts your integration timeline: does the platform... more »
Adamo vs WebRTC benchmarking: Teleoperation under poor networks
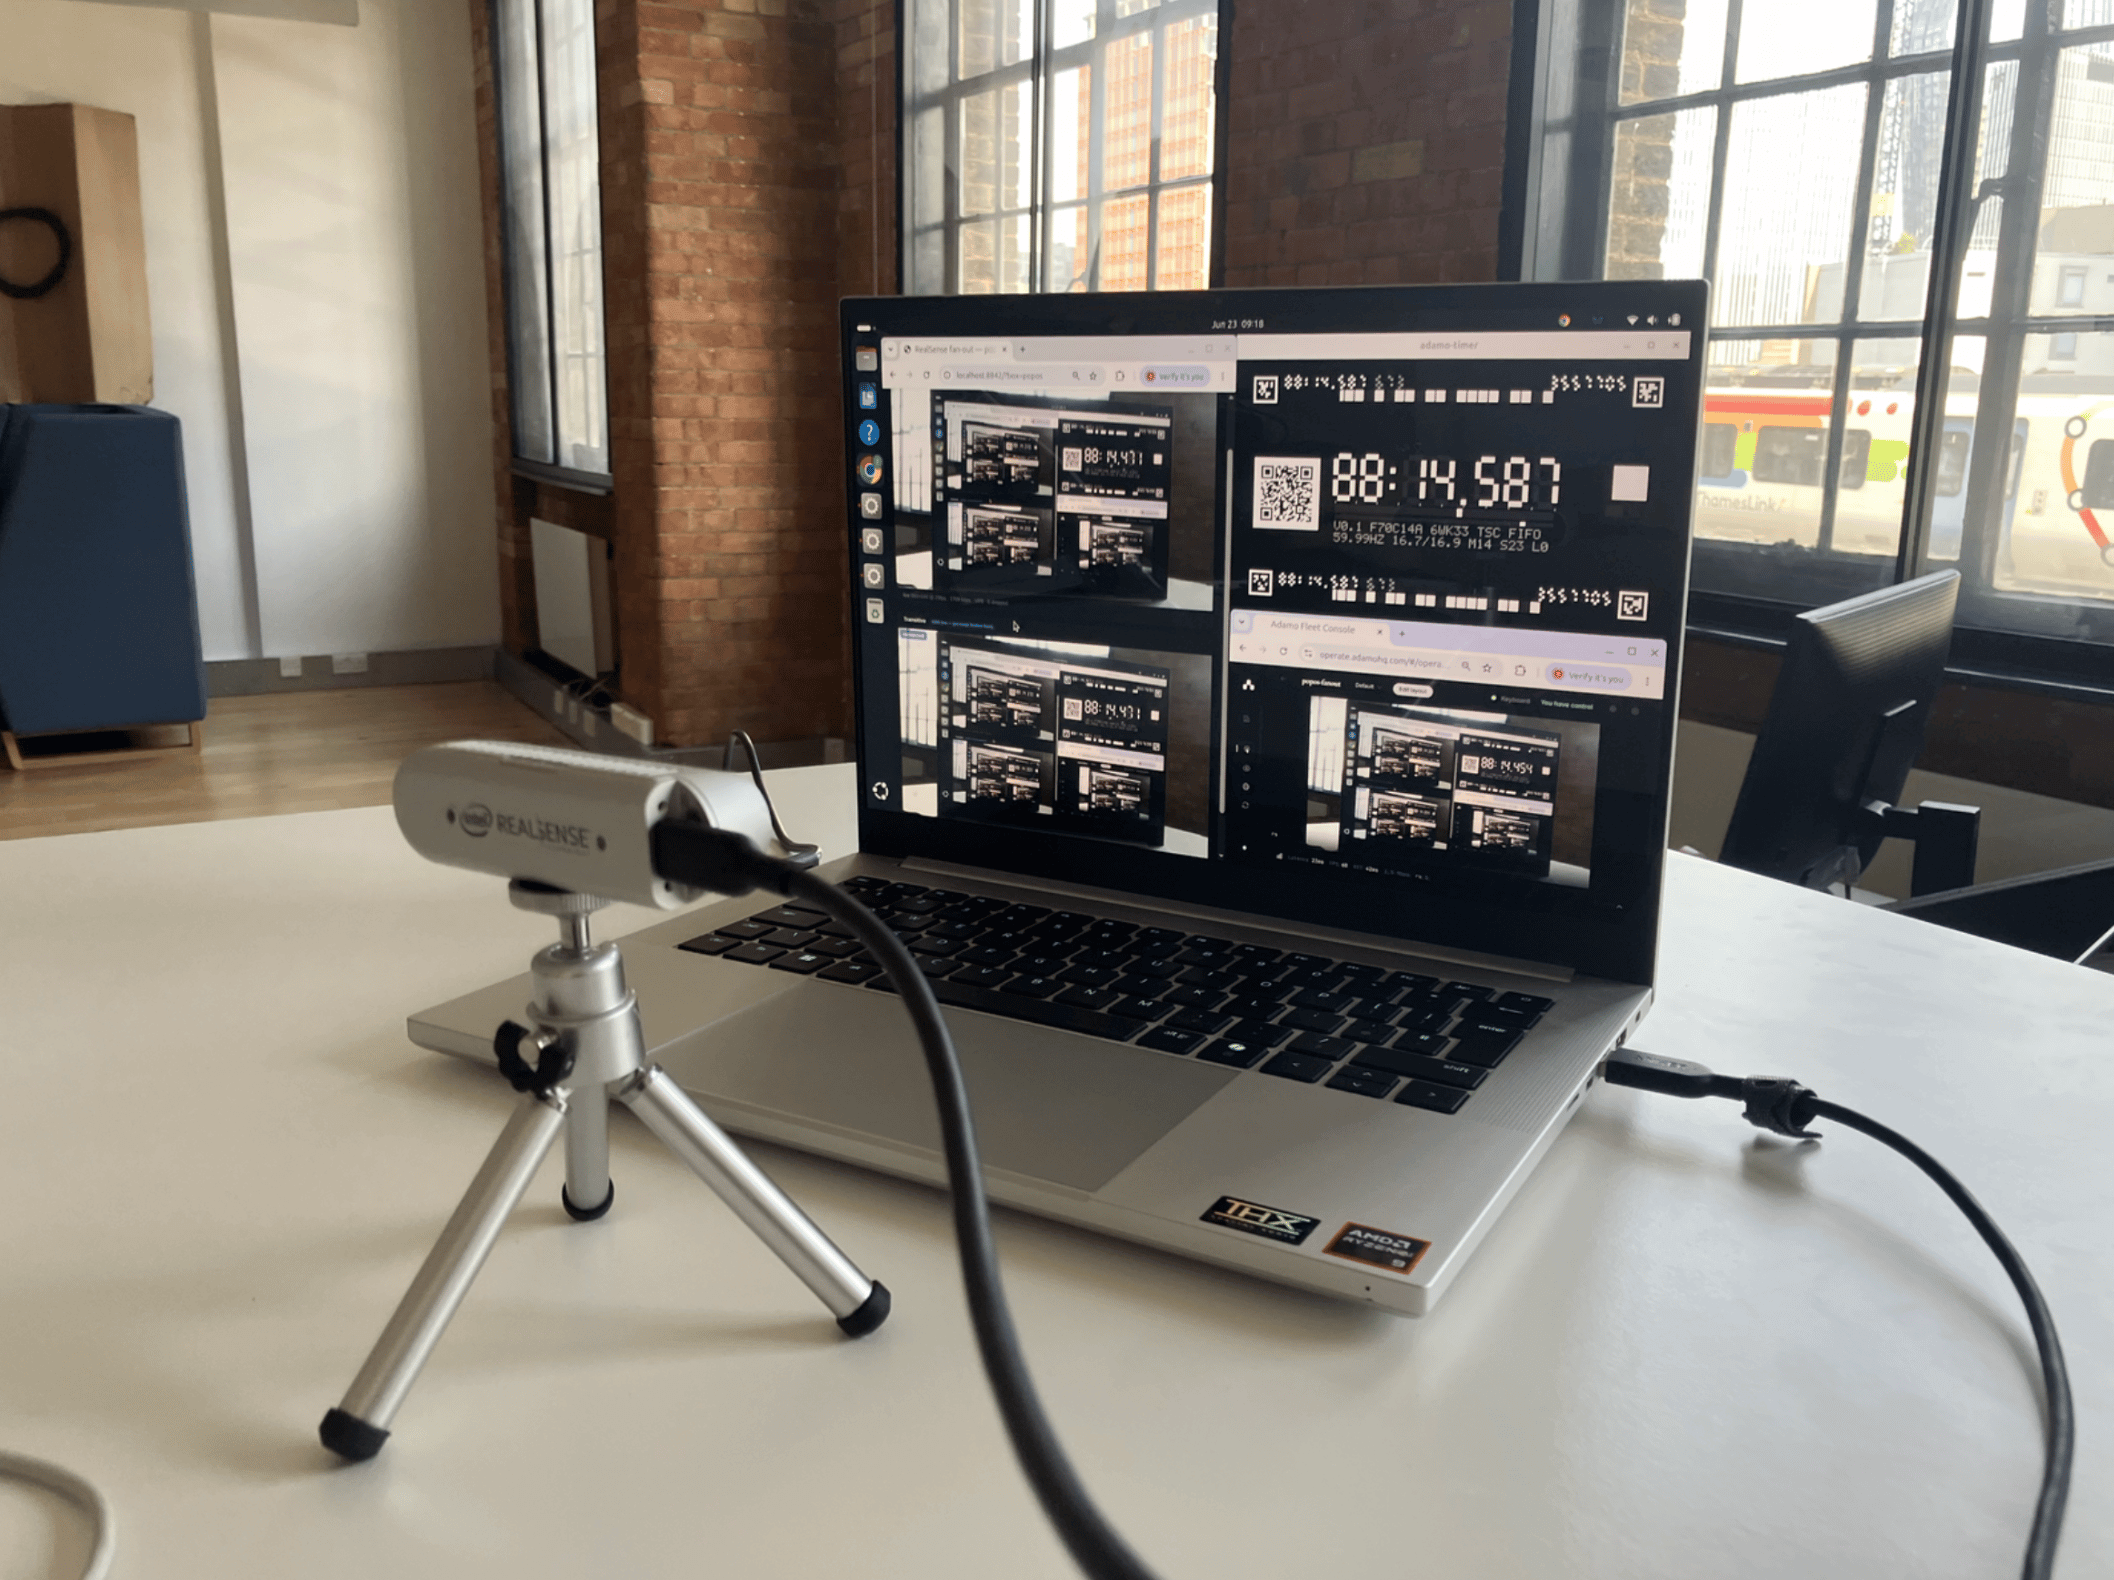
Why reliability under packet loss, not best case latency, is the number that indicates true performance of a teleoperation platform. TL;DR. A... more »
Why WebRTC Fails Teleoperation, and Why Adamo Wins
WebRTC was built for video calls, not teleoperation. The gap shows up the moment a robot moves. TL;DR: WebRTC carries everything that is not audio or video... more »
Remote Operation for Autonomous Vehicles at Low Latency
TL;DR: Need a remote operation solution for autonomous vehicle testing? Use a managed platform like Adamo that pairs sub 40ms streaming with 24/7... more »
Adamo's Sub-40ms Latency: The Fastest Teleop Stack in Robotics
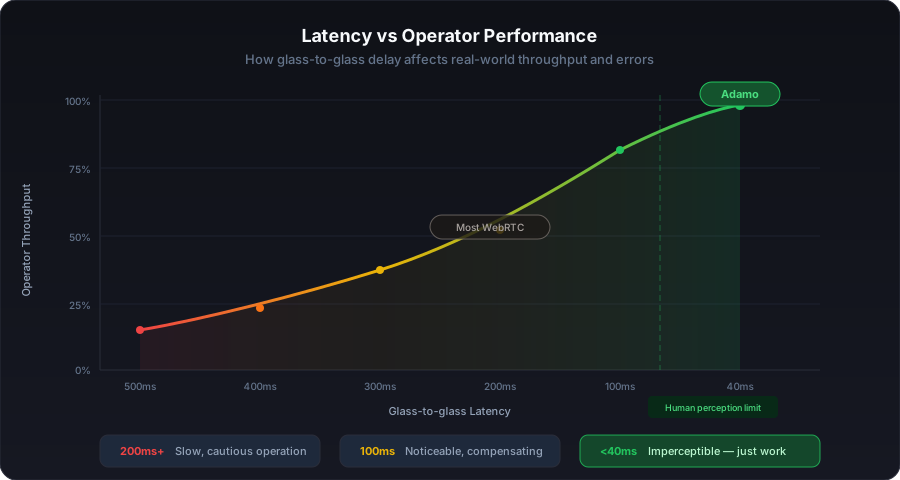
At Adamo, we built our teleop stack around a simple belief: latency is the single biggest bottleneck in robotics teleoperation today. Not video quality.... more »