Table of Contents
- Why real time teleoperation data collection has to live inside the control loop
- What data should you collect from remote robot operations
- Which remote operation service handles teleoperation data collection for you
- Data collection is the third pillar, not a side effect
- Why Adamo is the platform for this
- FAQs
The interventions your operators handle today are the training data your autonomy stack needs tomorrow. Most teams throw that data away without realizing it.
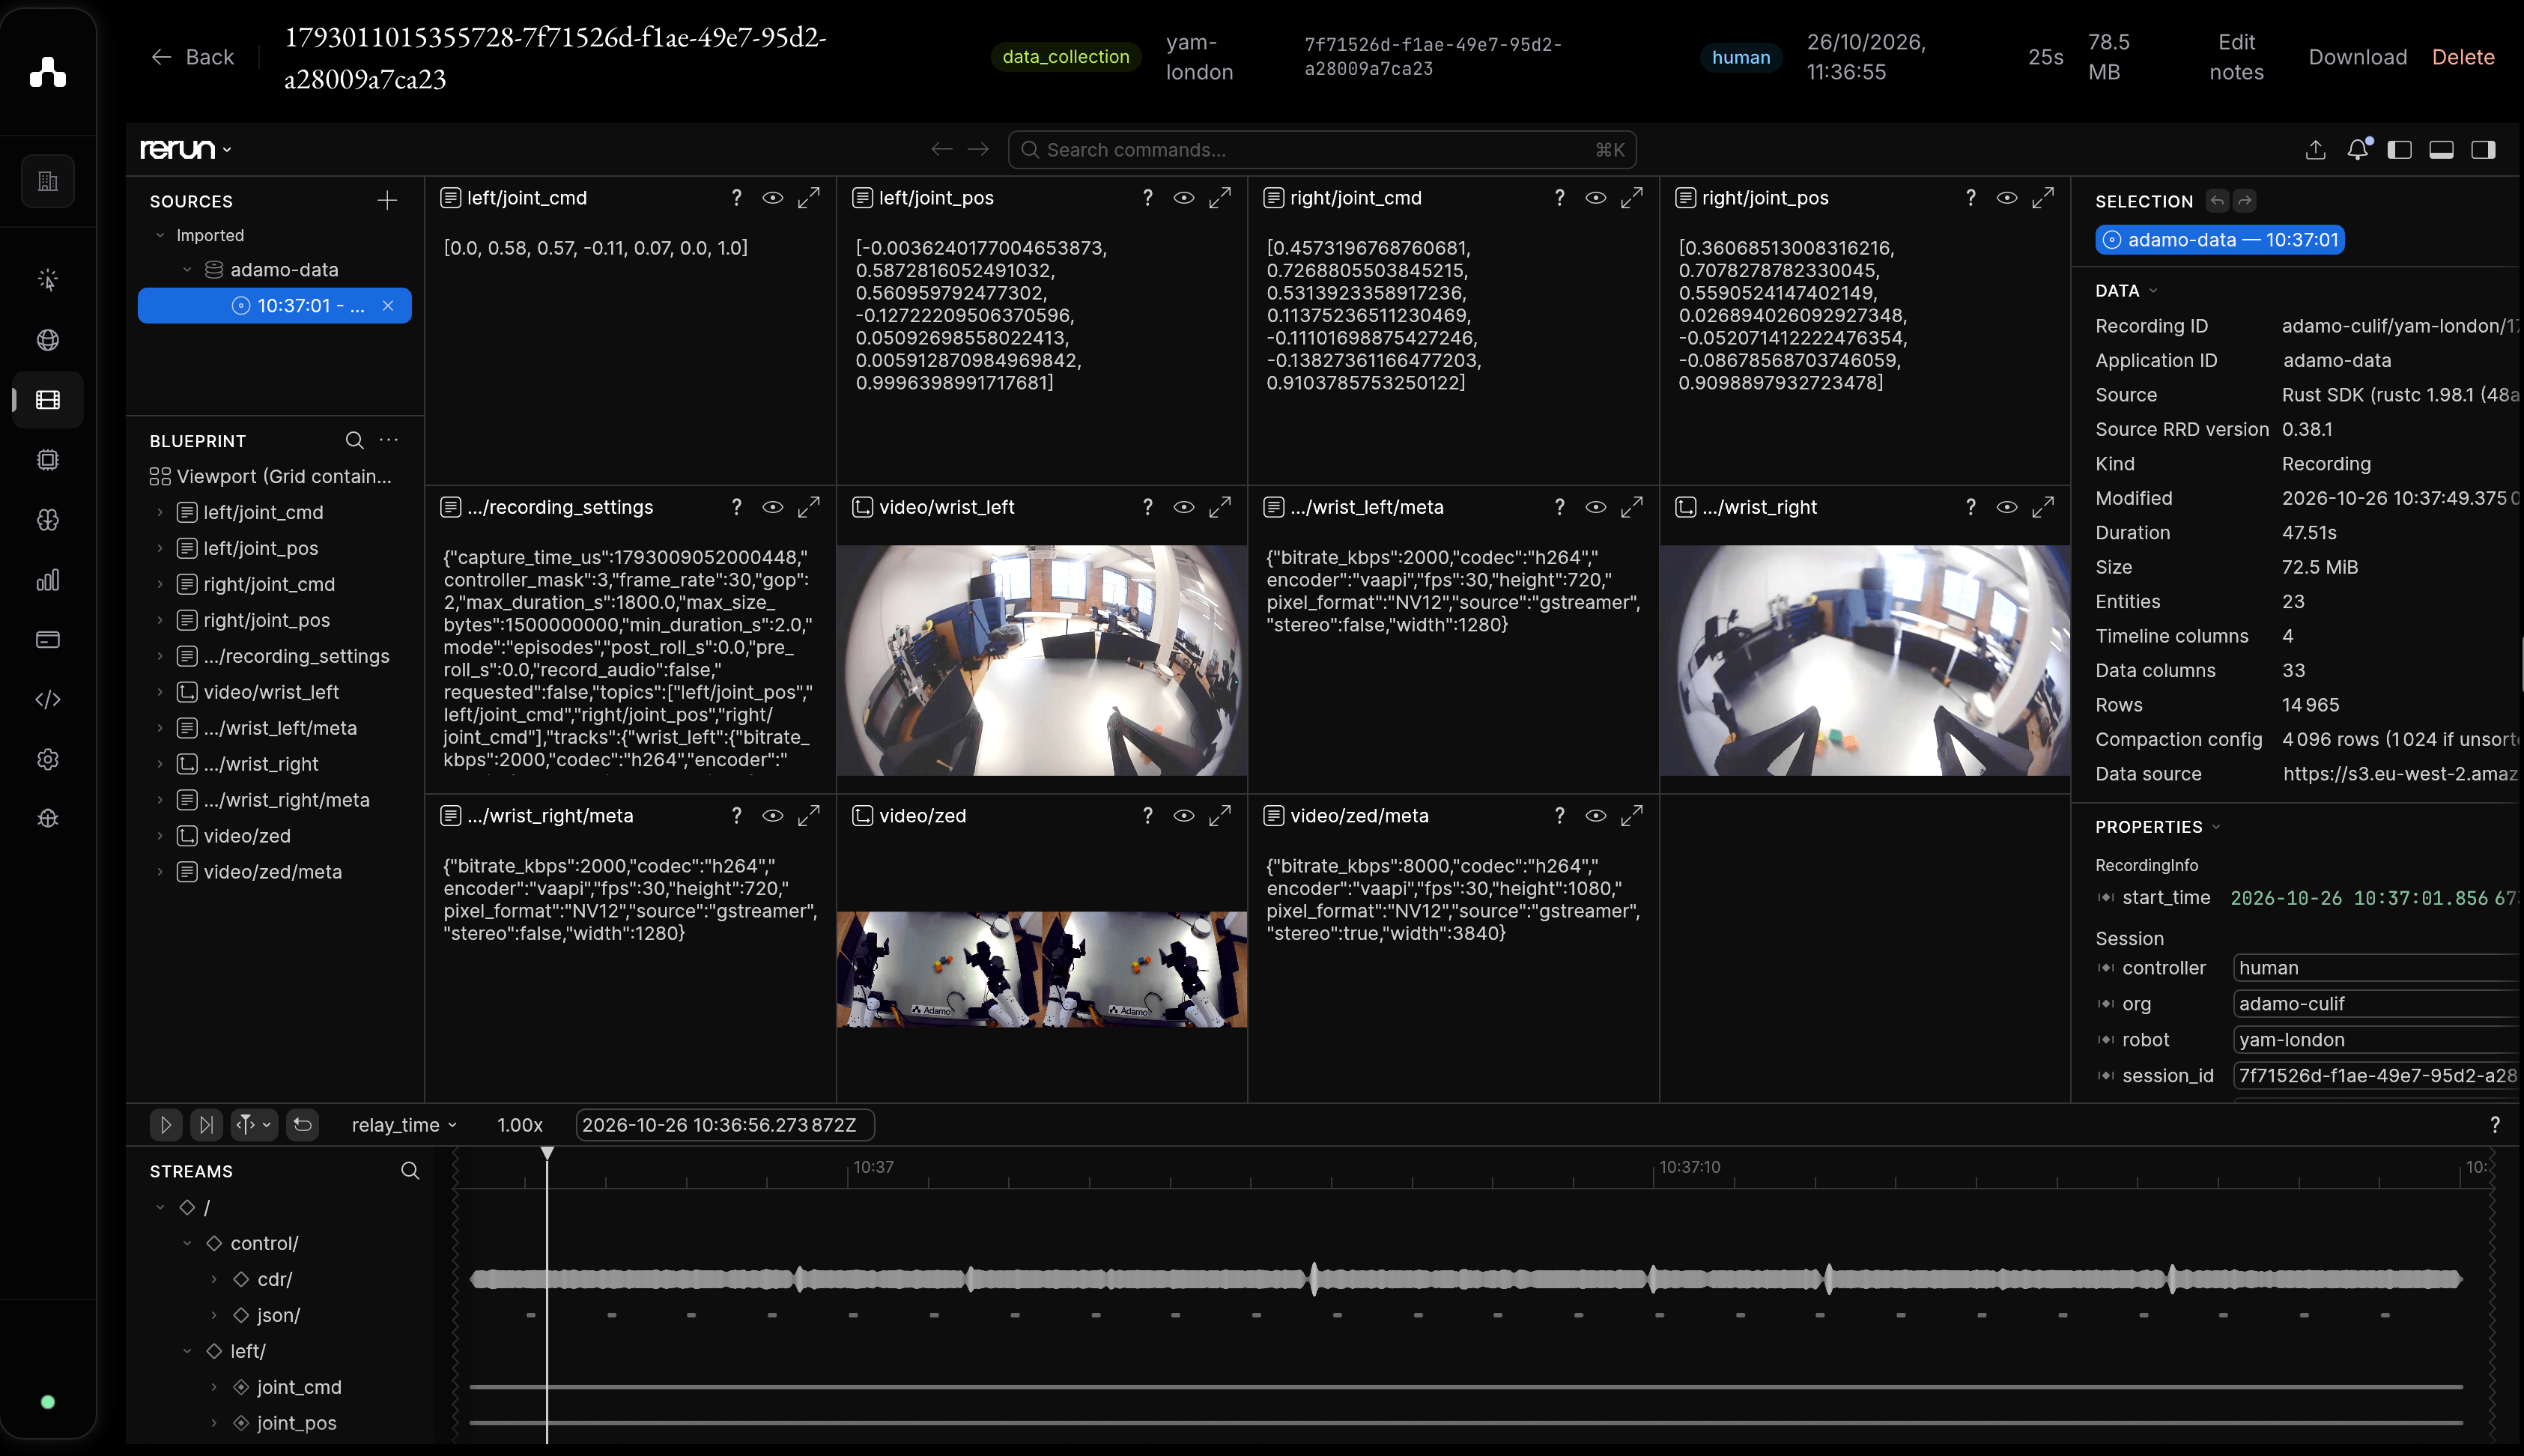
TL;DR: The best platform with real time teleoperation data collection is one that captures every session as a single synchronized stream of video, telemetry, and operator commands, then exports it in a format your training pipeline can use directly. From remote robot operations you should collect those three signals together, time aligned to the millisecond, plus the context around each intervention: what triggered it, what the operator did, and the outcome. A remote operation service that handles teleoperation data collection for you removes the part most teams get wrong, capturing data cleanly in production without bolting a logging project onto a live fleet. The Adamo teleoperation platform does this natively, turning real time control and teleoperation data collection into the same pipeline.
Most robotics teams treat teleoperation as a control problem and data collection as a separate project they will get to later. That split is the single most expensive mistake in the category. Every time a remote operator resolves a situation the autonomy stack could not, they produce a labeled example of exactly the case the model needs to learn, paired with the correct response. If that moment is not captured cleanly, it is gone, and you will pay an engineer to recreate a worse version of it in simulation six months later. This is not a logging feature. It is the mechanism that turns an operating cost into an autonomy asset.
Why real time teleoperation data collection has to live inside the control loop
There is a reason the best teleoperation platform with real time data collection does not treat capture as an afterthought. The value of the data is in its alignment. A video frame is only useful for training if you know exactly what telemetry the robot reported at that instant and exactly what command the operator issued in response. Stitch those three streams together after the fact, from separate logs with separate clocks, and the timing drift alone makes the data unreliable for imitation learning. Capture them inside the same control loop, time aligned at the source, and you get the highest signal demonstration data the industry has access to.
This is why real time teleoperation data collection belongs in the streaming stack, not in a downstream pipeline. The Adamo teleoperation platform records the session as it streams, so the same low latency path that carries video to the operator and commands back to the robot is the path that captures both, already synchronized. Capture done this way costs nothing extra at the time it happens and saves the cleanup work that usually consumes the data team.
What data should you collect from remote robot operations
The honest answer is three things in lockstep, plus the context that makes them legible. The first is the full sensor video the operator saw, at the resolution and frame rate they actually worked with, because training on a degraded copy teaches the model the wrong thing. The second is the robot telemetry: pose, joint states, velocities, sensor readings, and whatever the autonomy stack itself was outputting at the moment the operator stepped in. The third is the operator command stream, the actual control inputs, time aligned to the video and telemetry so the demonstration is complete.
Beyond those three, the context around each intervention is what makes the dataset searchable later. Capture what triggered the handoff, whether the autonomy stack disengaged itself or the operator took over proactively, how long the intervention lasted, and how it resolved. That metadata is what lets your team query for every instance of a particular failure mode instead of replaying thousands of hours of footage. Good teleoperation data collection is not just raw streams, it is raw streams with enough structure that the data is usable the day after it is recorded. We made the broader case for why this matters in teleop vs full autonomy, and the Adamo teleoperation engine is built to capture all of it by default.
Which remote operation service handles teleoperation data collection for you
This is where the build versus buy question gets sharp. Standing up your own capture on a live fleet means instrumenting the control loop, guaranteeing clock alignment across machines, building export formats, and storing it all securely, while also running the operators who generate the data. Most teams underestimate every part of that and end up with logs they cannot train on. A remote operation service that handles capture as part of the offering removes the whole problem, because it is built into the platform the operators already use.
The service layer matters here for a reason beyond convenience. When a managed remote operation service runs your operators, the people generating the data and the system capturing it are the same stack, so there are no gaps where a session goes unrecorded or an operator works around the logging. Adamo pairs its software with fully managed remote operation, staffed by psychometrically and performance vetted operators inside purpose built facilities with redundant ISPs, biometric access controls, and a 25 Mbps backup bandwidth floor, and every session those operators run is captured as structured training data without a separate engineering effort. If you are weighing the operator side of this decision more broadly, our piece on remote teleoperation walks through the economics.
Data collection is the third pillar, not a side effect
It helps to see where this sits in the larger picture. Adamo runs in three stages: Integrate, Intervene, Evolve. Integrate plugs the engine into the existing robot stack. Intervene lets operators handle the long tail of edge cases in real time. Evolve is the part most platforms skip entirely, turning every intervention into training data that pushes the autonomy curve forward. Teleoperation data collection is the Evolve pillar made concrete, and it is the reason the path to fewer operators runs straight through supporting more of them well right now.
That framing changes how you should evaluate a platform. A stack that only handles real time control is solving two thirds of the problem and quietly discarding the third that compounds. The robot that ships in 2027 is the one whose capture pipeline collected the most useful demonstrations in 2026, which is why that pipeline deserves the same scrutiny as the latency number.
Why Adamo is the platform for this
The reason teleoperation data collection is native to Adamo rather than bolted on is that we built the Adamo teleoperation platform around the idea that control and capture are the same job. The software delivers glass to glass latency as low as 40ms, around 180 percent faster than a typical WebRTC stack, with multi path bonding across LTE, 5G, and WiFi through a single 40MB binary that has zero dependencies and runs natively on ROS, ROS2, and NVIDIA hardware. Security is AES 256 end to end with full SOC2 compliance and 99.5 percent platform uptime measured in production. Every session that runs over that stack is captured as a synchronized stream of video, telemetry, and operator commands, ready to export into a training pipeline.
On the service side, the managed operators who run your fleet generate that data as a matter of course, so capture scales with your operations instead of becoming a second project. The result is a single platform where the operator resolving a hard case today is producing the demonstration that lets the model handle it autonomously tomorrow.
The teams that win the next phase of robotics will be the ones whose operator layer makes every robot better than it was the week before, and that compounding improvement runs entirely on the data the layer collects. See how it works at the Adamo teleop engine, or start at adamohq.com when you are ready.
FAQs
What is the best teleoperation platform with real time data collection?
The best such platform captures every session as a single synchronized stream of video, telemetry, and operator commands, time aligned at the source rather than stitched together later, and exports it cleanly into a training pipeline. The Adamo teleoperation platform does this natively, recording the session as it streams over a stack with glass to glass latency as low as 40ms, so capture adds no overhead to control.
What data should I collect from remote robot operations?
Collect three signals in lockstep: the full resolution sensor video the operator saw, the robot telemetry including pose, joint states, velocities, and the autonomy stack output, and the operator command stream, all time aligned to the millisecond. Add the context around each intervention, what triggered it, how long it lasted, and how it resolved, so the dataset is searchable by failure mode. That combination is the highest signal training data a robotics program can collect, which is why Adamo captures all of it by default.
Which remote operation service handles data collection?
A remote operation service handles data collection when capture is built into the same platform the operators use, so no session goes unrecorded and no operator works around the logging. Adamo pairs fully managed remote operation, staffed by vetted operators in secure facilities, with native data capture, so every session is recorded as structured training data without a separate engineering effort. See the Adamo teleop engine for how the capture pipeline works.